Workshop on Safety Analysis for Autonomous System: Practical Perspectives and Recent Advances
December 14, 2026
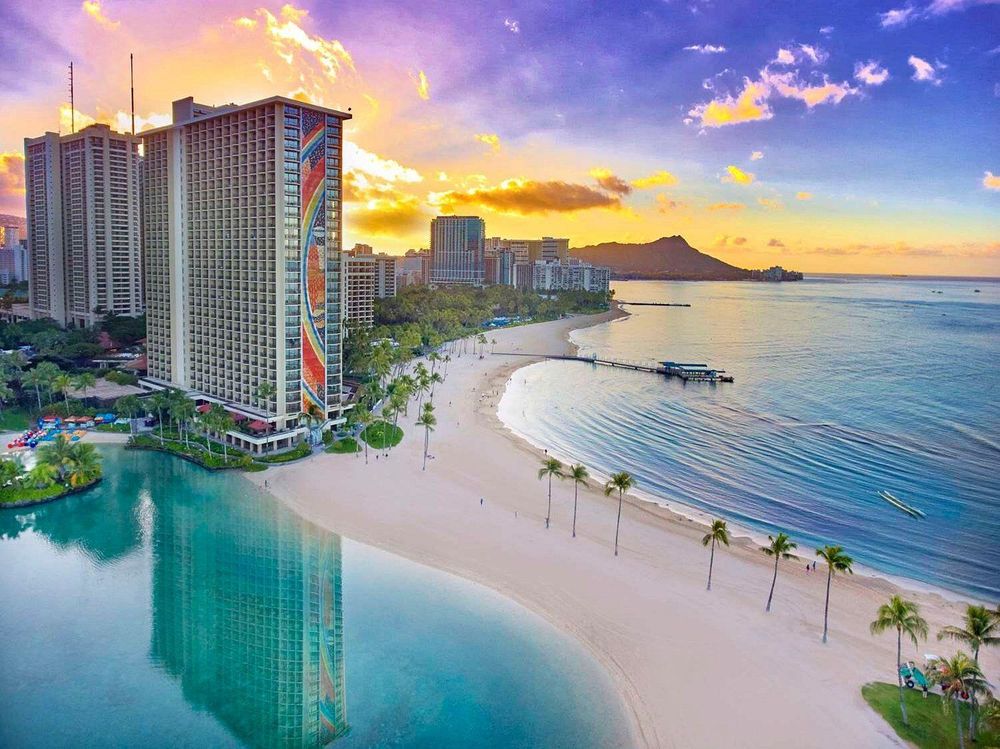
Hilton Hawaiian Village in Honolulu, Hawaii, USA.
65th IEEE Conference on Decision and Control
The deployment of autonomous systems in the real world, such as self-driving vehicles and unmanned aerial systems, requires rigorous methods for verifying and reasoning about whether a system can maintain safety, broadly understood as the ability to enforce constraints on system behaviors. Safety is one of the most fundamental challenges in deploying autonomous systems in the real world. A diverse landscape of methods has emerged to address this challenge, drawing on techniques from control theory, optimization, and formal verification.
Among these, Control Barrier Functions (CBFs) and Hamilton-Jacobi (HJ) Reachability Analysis have become two prominent families: while they share the overarching goal of performing safety analysis for control systems, they are rooted in distinct mathematical foundations, and hence offer different insights and lend themselves to different analysis and design tools. They also share common open challenges, such as scalability to high-dimensional systems and integration with learned components.
Beyond these two frameworks, perspectives from formal methods offer complementary tools for specifying and verifying safety properties, and increasingly intersect with control-theoretic approaches. Finally, recent advances in machine learning-based methods, such as physics-informed machine learning and reinforcement learning, emerge as effective tools for constructing the safety certificates or conducting the safety analysis.
This workshop aims to bring together researchers working across this broader space—centered on CBFs and HJ reachability, while engaging with adjacent perspectives from formal methods, and bringing in machine learning techniques for advancing design and analysis methods—to exchange ideas and accelerate progress towards the safe deployment of autonomous systems.
Keynote Speakers
Alessandro Abate
University of Oxford
Aaron Ames
Caltech
Nadia Figueroa
University of Pennsylvania
Claire Tomlin
UC BerkeleyWorkshop Schedule
Introductory Remarks
Keynote Talk #1
Keynote Talk #2
Cofee Break
Recent Advances in CBF and HJ reachability methods
Lunch Break
Keynote Talk #3
Keynote Talk #4
Cofee Break
Lightning Talks
Panel Discussion
Closing Remarks
Call for Contribution
We welcome submissions on recent advances and practical perspectives in safety analysis for autonomous systems, including but not limited to the areas below. Submissions may be either extended abstracts (up to 3 pages) or full papers (up to 6 pages), in the CDC submission format. The workshop is non-archival. Accepted papers will be presented as 5-minute lightning talks at the workshop.
Areas of Interest:
- Hamilton-Jacobi reachability analysis
- Control barrier functions
- Safety filtering techniques
- Data-driven and learned safety certificates
- Probabilistic and statistical safety guarantees
- Safety under perception uncertainty and partial observability
- Safe multi-agent and human-robot interaction
- Formal methods and temporal logic specifications
- Benchmarks, case studies, and lessons from real-world deployment
- Verification of learning-based safety certificates
- Safety certificates and control methods for high-dimensional systems
Submission Link: OpenReview
Deadline (extended): November 6 November 15, 2026, 11:59 pm Anywhere on Earth
For any queries, please contact us at: cdc26safetyworkshop@googlegroups.com
Organizers